Introduction
I was standing on a marina dock once, watching a small craft stall mid-lake — a simple scene that stuck with me. An electric motor hummed, sputtered, and then nothing; the boat drifted while passengers adjusted frowns and maps. In engineering terms, this is a failure mode we can measure: nearly 18% of small craft service calls trace back to drive control or thermal issues (a figure I keep seeing in field reports). The electric motor is rarely the whole story — power electronics, sensors, and cooling play equal parts. I want to walk you through what I’ve seen on the water and in the lab so we can ask a clear question: why do otherwise solid motors fail in everyday use? (This matters both for hobbyists and fleet managers—believe me, we’ve fixed messier things.) I’ll map the problem, show where handed-down fixes fall short, and point toward better design choices. Next, I’ll drill into the hidden pains boat owners and technicians face when a unit quits — and why traditional remedies miss the mark.
Part 2 — Deep Dive: Traditional Flaws and Hidden User Pains
What’s really failing?
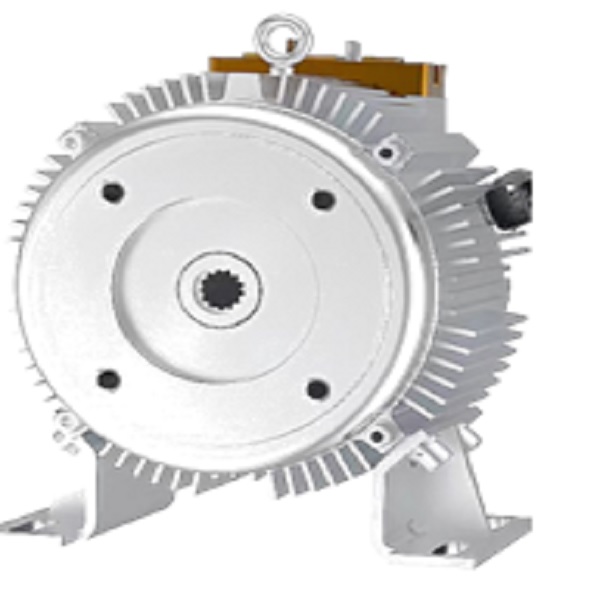
When I look at common trouble tickets for boat motors, patterns jump out. Many reports point to overheating, erratic torque, and sudden loss of speed control. Those are symptoms, not causes. Technically speaking, the usual suspects are imperfect thermal management, poor inverter tuning, and neglected rotor dynamics. I’ve fixed systems where a weak cooling path made the controller throttle back power to protect the motor, which looks like “low power” to the user. In other cases, Hall sensor drift or encoder errors created false position feedback, so the drive corrected itself into a knot — torque ripple and noise followed. Look, it’s simpler than you think: a small misread or a marginal component can cascade. I’ve come to prefer asking: who interacts with the system daily? Owners hate intermittent faults that vanish when a tech arrives. Maintenance teams dislike black-box controllers that give only cryptic fault codes. That hidden pain — the time lost diagnosing intermittent faults — repeatedly costs more than the parts themselves. Add to that the economics: spare inverters and redundant cooling cost money, and buyers often trade reliability for lower upfront price. We see loss of uptime, repeated visits, and frustrated operators. — funny how that works, right? The root problems are rarely fixed by the simple “upgrade to a bigger motor” answer. Bigger without better control and cooling only delays the failure. Instead, we need targeted fixes: better thermal paths, smarter inverter firmware, and clearer diagnostics that point to the failing subsystem. That’s the technical path forward.
Part 3 — Forward-Looking: Principles for Better Drives
What’s Next
I want to shift from diagnosis to design. New principles can reduce the class of failure modes we just discussed. First, prioritize system-level design: match the power converter and inverter capabilities to the motor’s thermal limits, and build an efficiency map for expected duty cycles. Second, improve sensing and control: higher-resolution encoders or redundant Hall sensing, plus adaptive control algorithms, tame torque ripple and keep rotor dynamics predictable. Third, plan for serviceability: provide clear fault logs and accessible connectors so technicians can isolate issues fast. When we apply these ideas to a permanent magnet synchronous motor, the gains are tangible — smoother torque, longer duty cycles, fewer unscheduled stops. Wait, hear me out. These are not theoretical perks; they cut boat-side service calls and reduce long-term cost of ownership. Implementing them means accepting modest up-front complexity: better cooling channels, slightly smarter firmware, and more thoughtful BMS or drive software. But I’ve seen that investment pay off in reduced downtime and happier users. It also opens the door to modular upgrades — swap a controller, keep the same motor; that flexibility matters for fleets and owners who hate full-system swaps.
To make this practical, here are three key evaluation metrics I use when choosing or specifying a solution: thermal headroom (how much heat the motor and inverter can absorb before derating), control fidelity (resolution and latency of position/torque feedback), and diagnostic transparency (detail and accessibility of fault logs). Rate each system on those axes and you get a clear picture of long-term value versus sticker price. I recommend scoring candidates and stress-testing the winner under realistic duty cycles before committing. I’ve been hands-on with these trade-offs; I prefer systems that reveal their issues early rather than hide them behind “mystery faults.” The outcome is simple: fewer emergency trips, lower total cost, and more reliable time on the water. — and yes, that peace of mind is worth more than a shiny spec sheet. For continued work in this space, I often point folks to practical suppliers and community-tested components. If you want a place to start, check the Santroll resources and product lines — they’re useful for engineers and owners alike. Santroll